Research & Projects
Research
Robotic Connector Manipulation - IIWA 14 Robot with NIST Board | RRoS Lab
Built simulation environment in NVIDIA Isaac Sim 4.5 for IIWA 14 to perform plug/unplug operations. Developed RL-based control policies and integrated computer vision for connector detection and pose estimation.
Publications
Google ScholarSolving Asset and Liability Management Using Cohort Intelligence and Goal Programming
IG Gala, A Nargundkar, Dr. Anand J Kulkarni (Advisor), A Shastri
Applied Cohort Intelligence and Goal Programming optimization techniques to address complex multi-objective asset and liability management challenges in financial systems.
Projects
Task-Aware Local RAG for Robot Procedure and Code Generation
Built a local RAG system using Ollama + FAISS to extract grounded contingency procedures & generate robot code with 40% reduction in hallucinations.
Achievements:
- Recall@5: 84% and MRR: 0.78 on 20+ documents
- Deployed for on-floor fault recovery support
- Generated control code for recovery actions with low latency
Real-Time Stock Market Ticker - Full Stack Web & Android App
Developed a real-time stock market ticker and portfolio management system with seamless UI/UX.
CiteLlama – Improving Citations with Context
Fine-tuned Llama 3.1 8B using LoRA on academic citations to generate accurate, grounded citations with 11% boost in quality.
Features:
- Implemented citation formatting for CVPR, AAAI, IEEE, ACM
- 11% boost in citation quality (BLEU + relevance)
- 50K+ academic citations dataset
Dexterous Manipulation - Throwing & Catching
Developed an RL-based framework for dexterous manipulation tasks using MuJoCo environments with hand models.
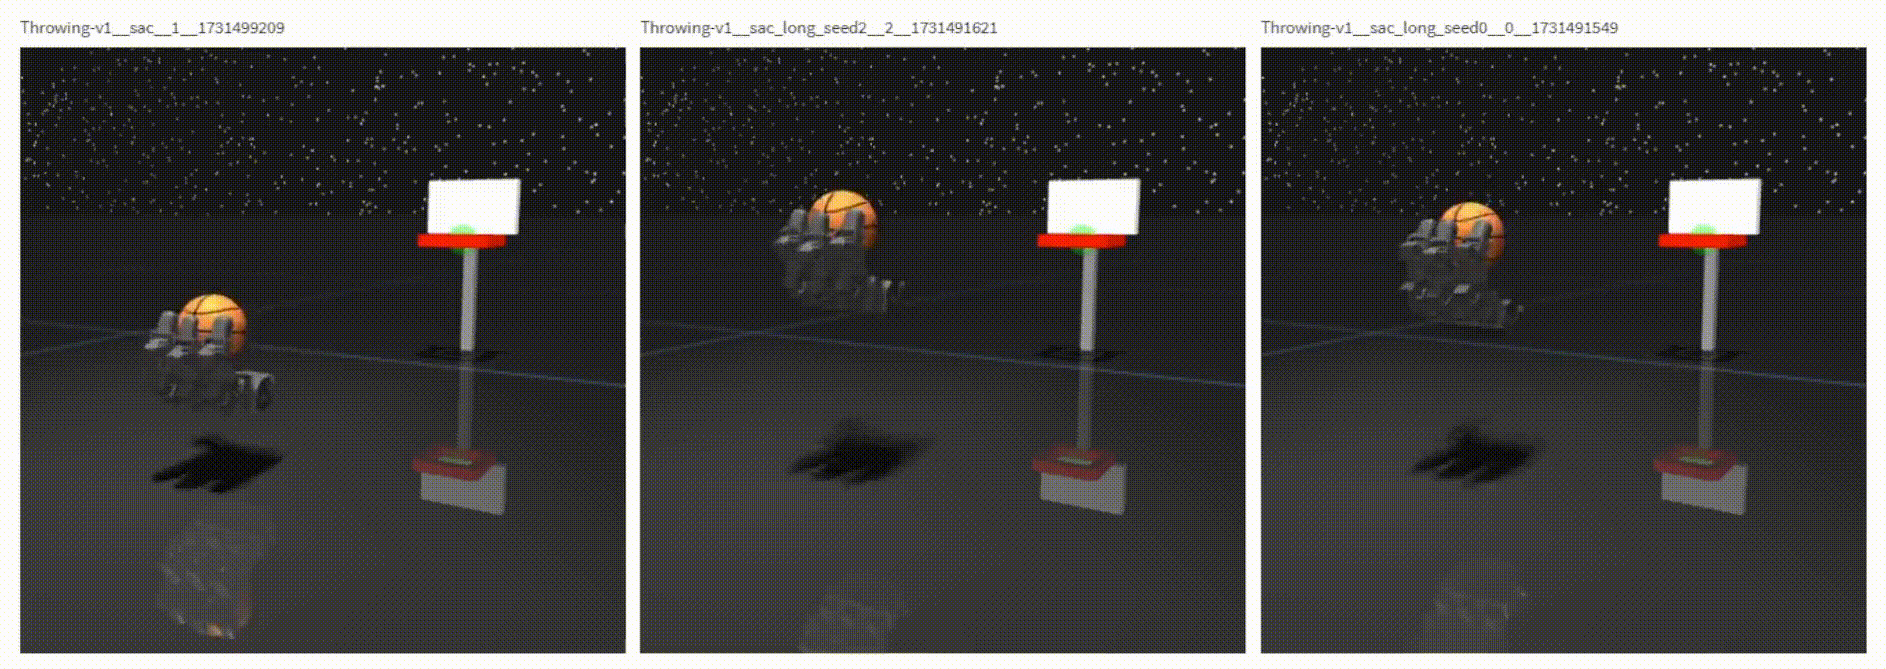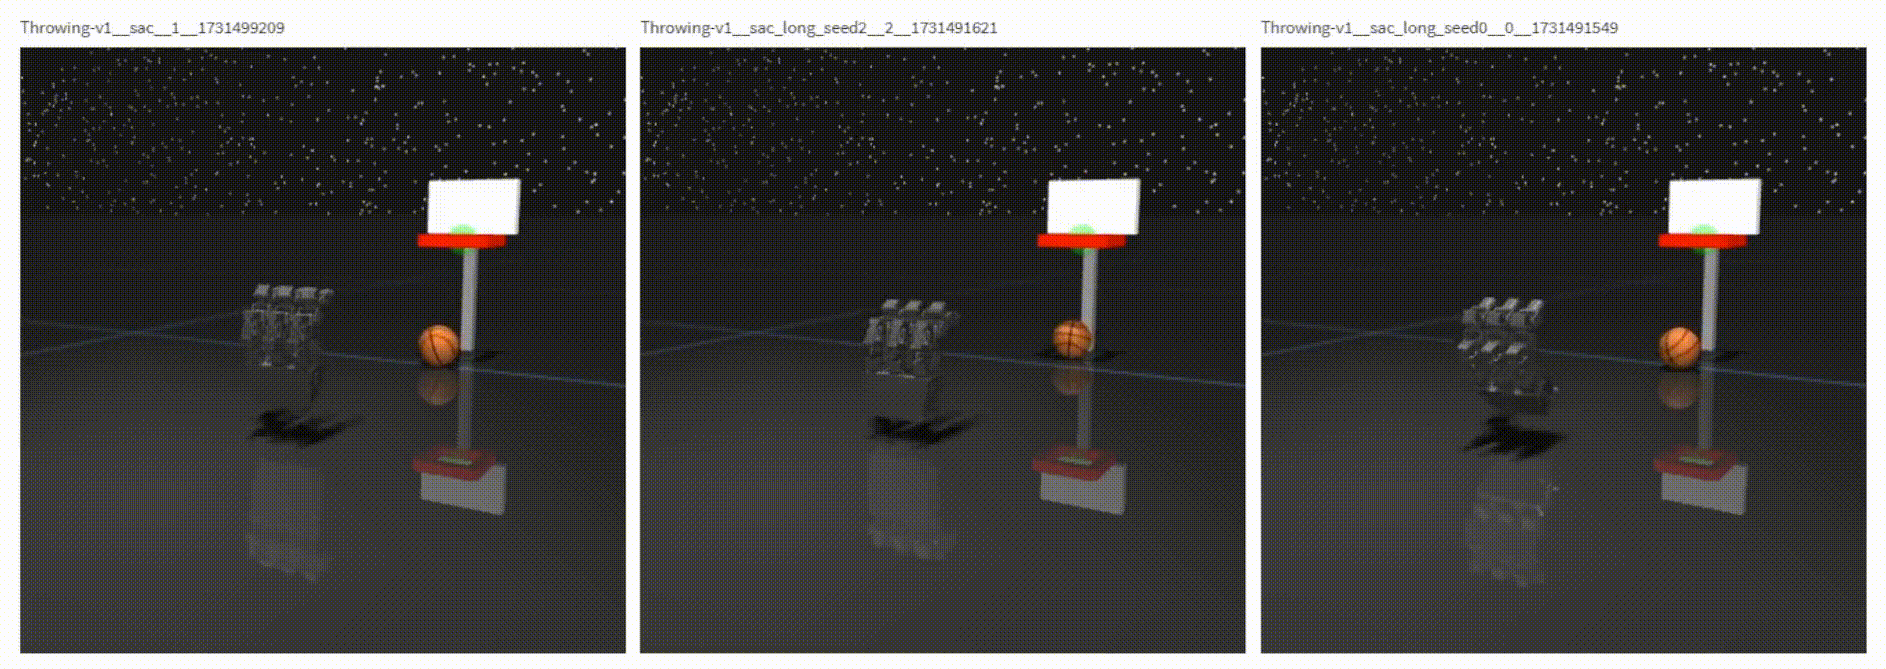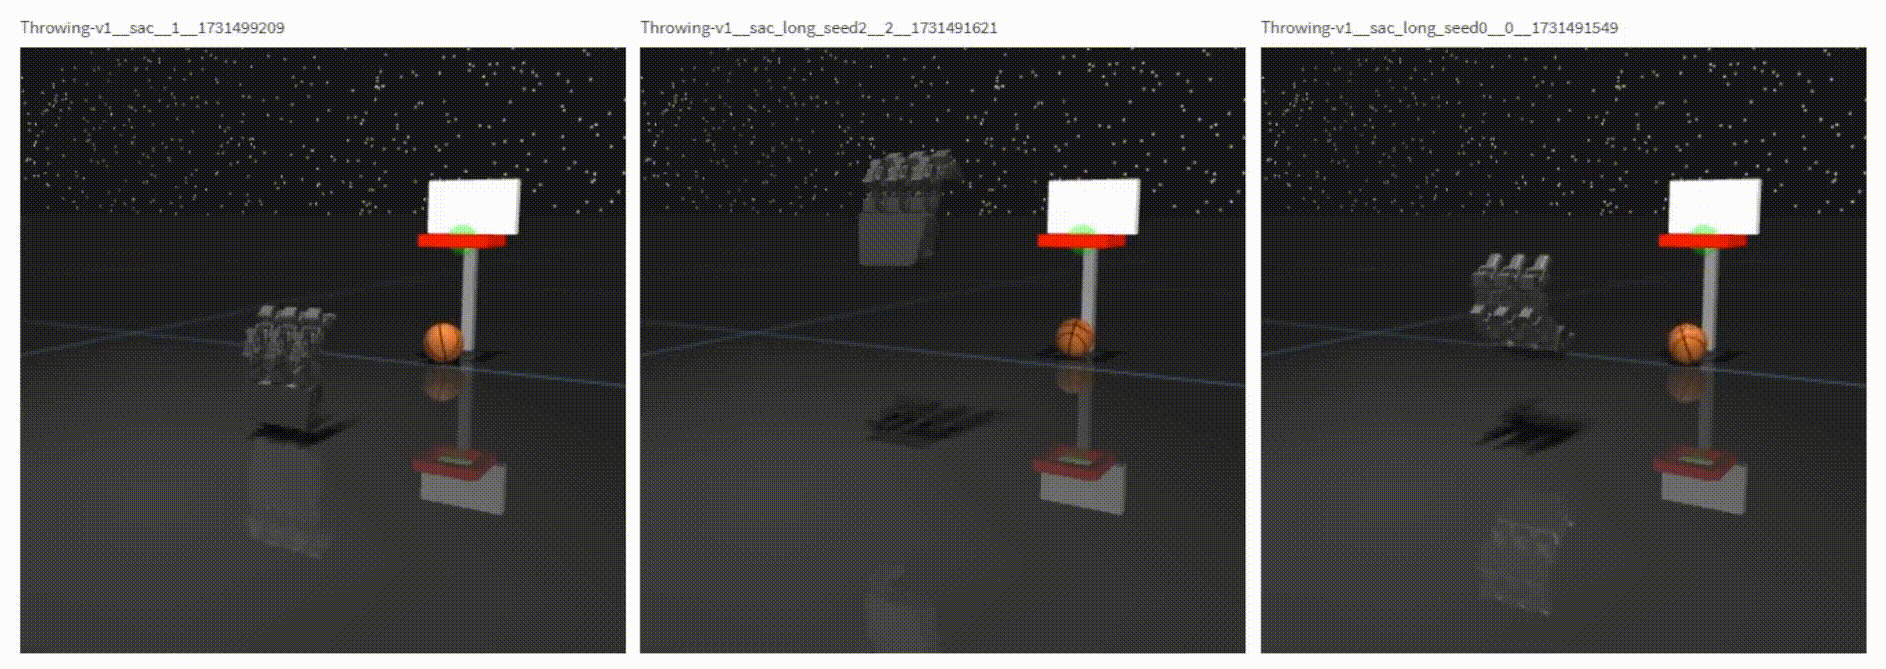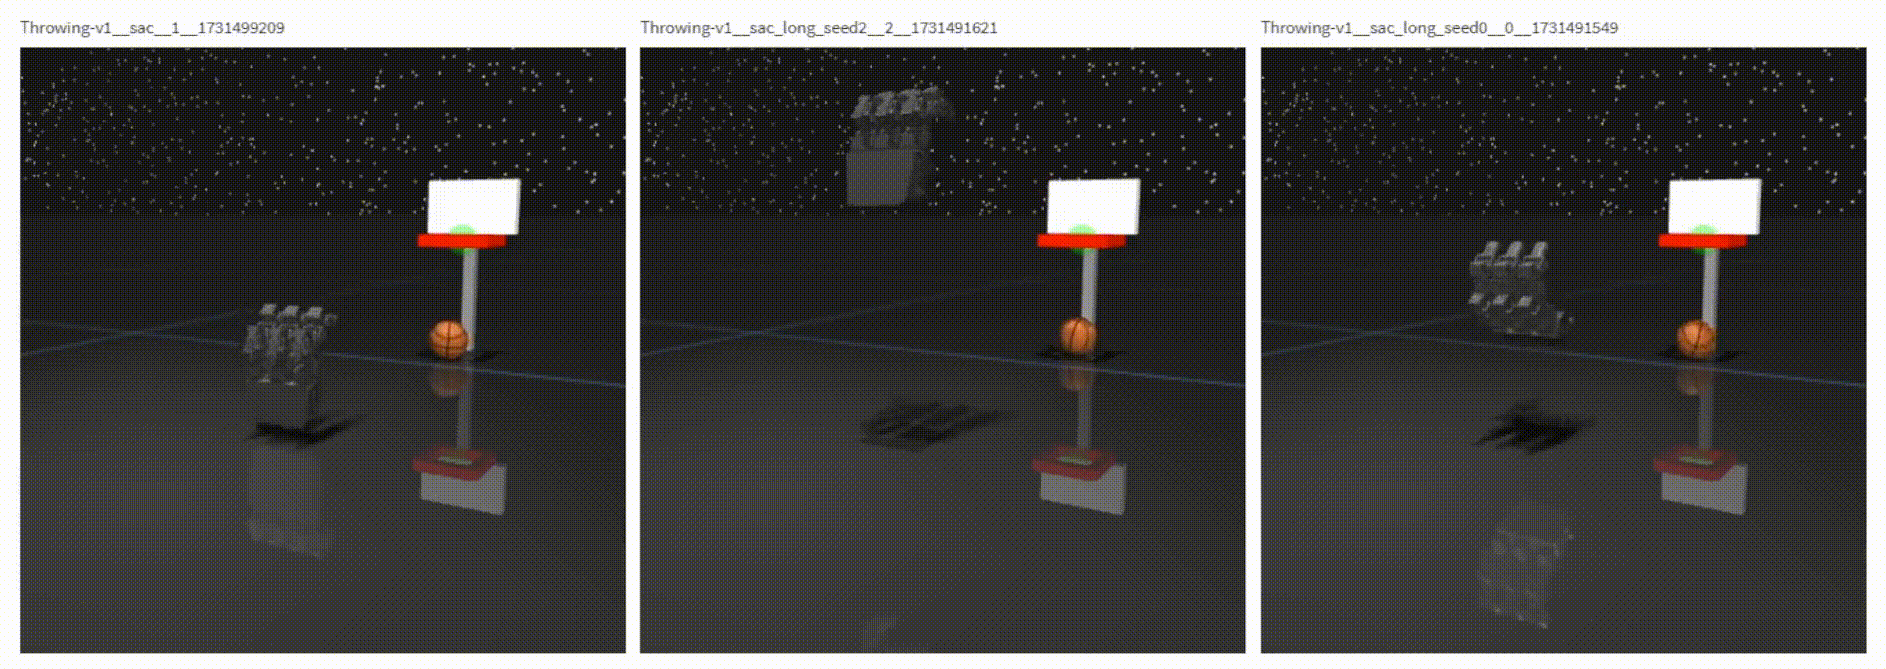 Throw Long
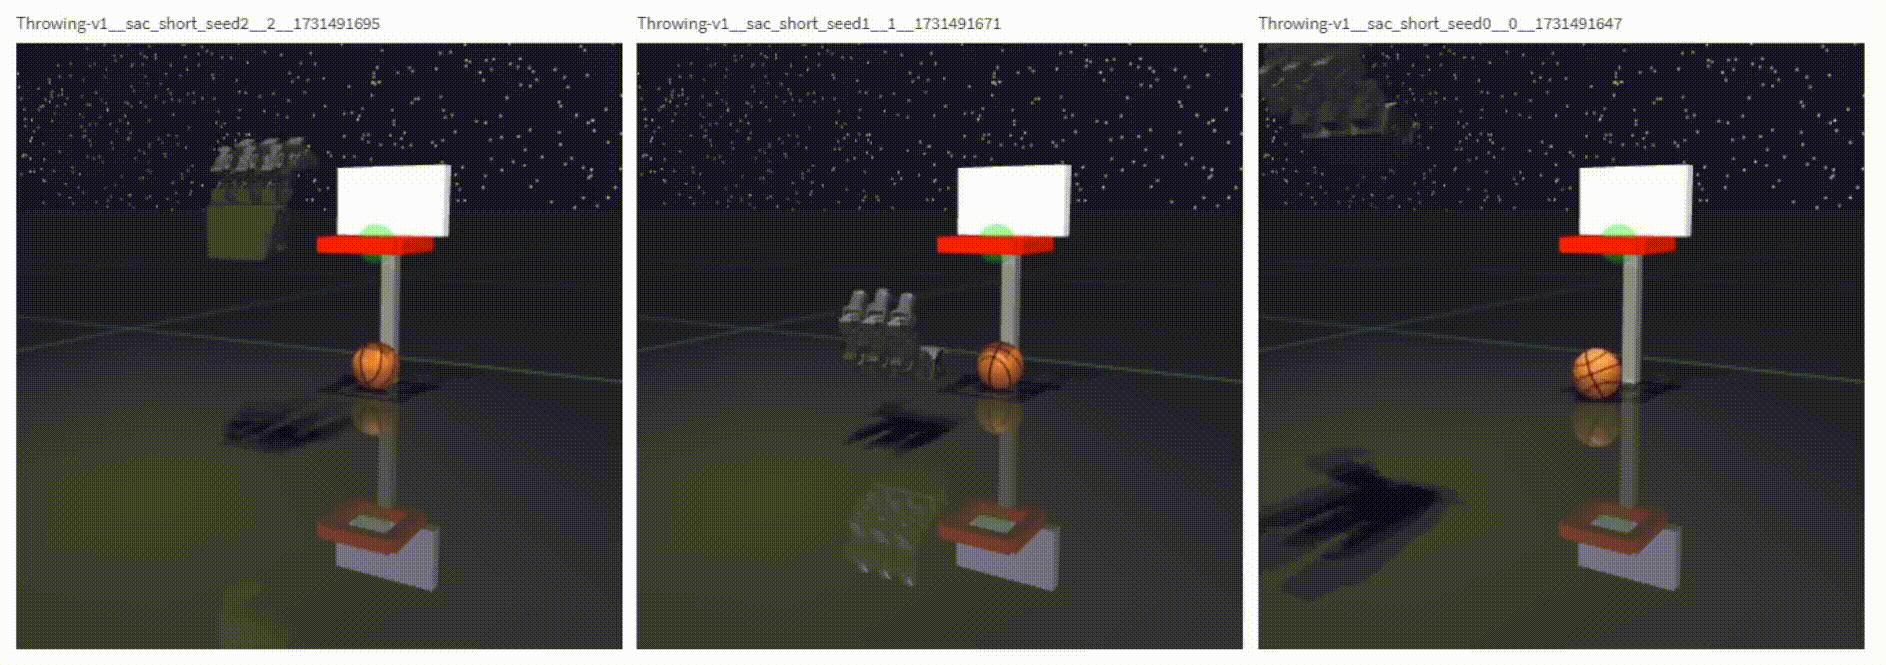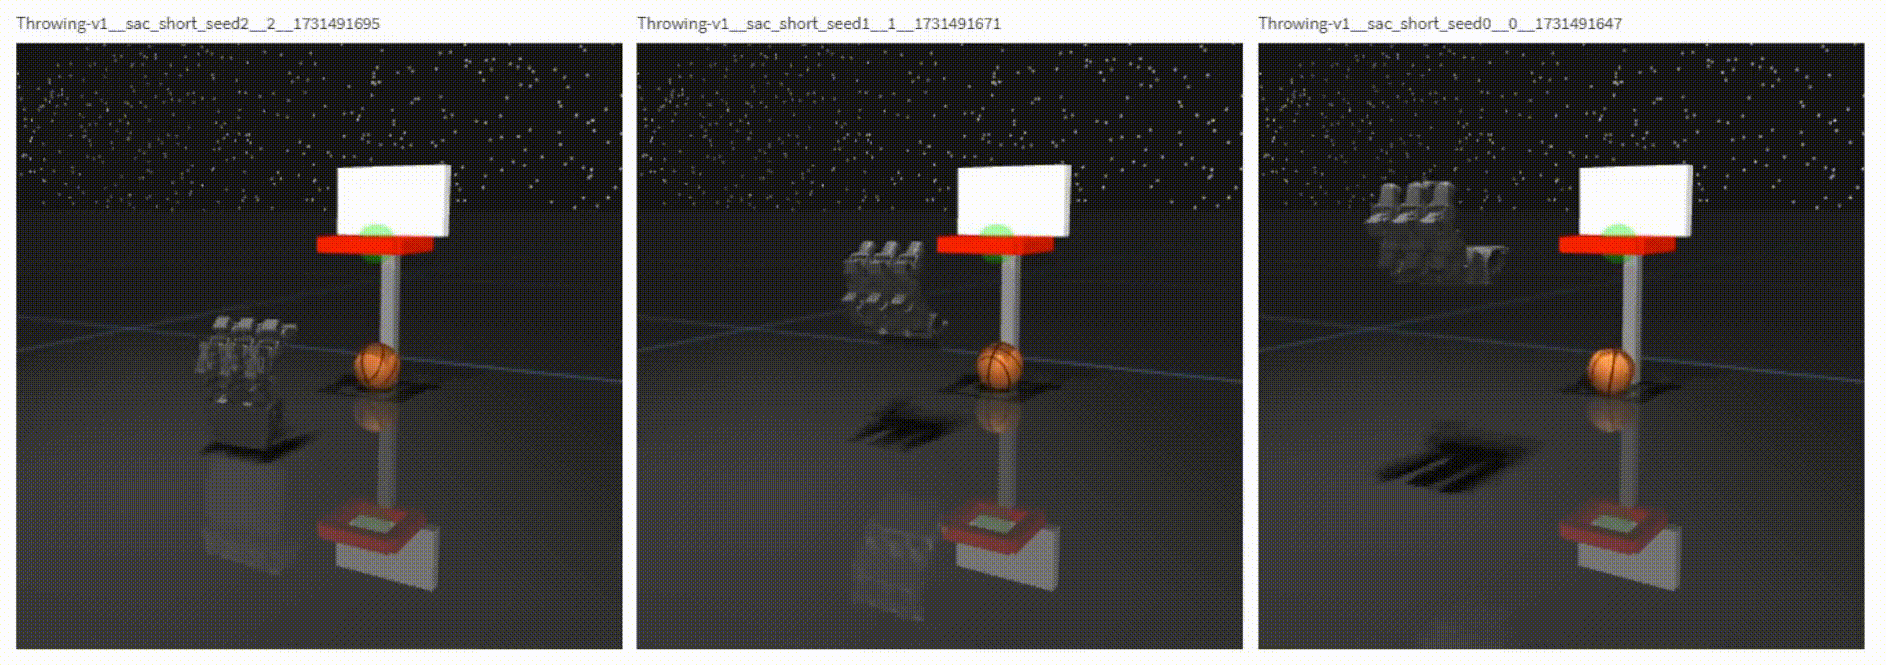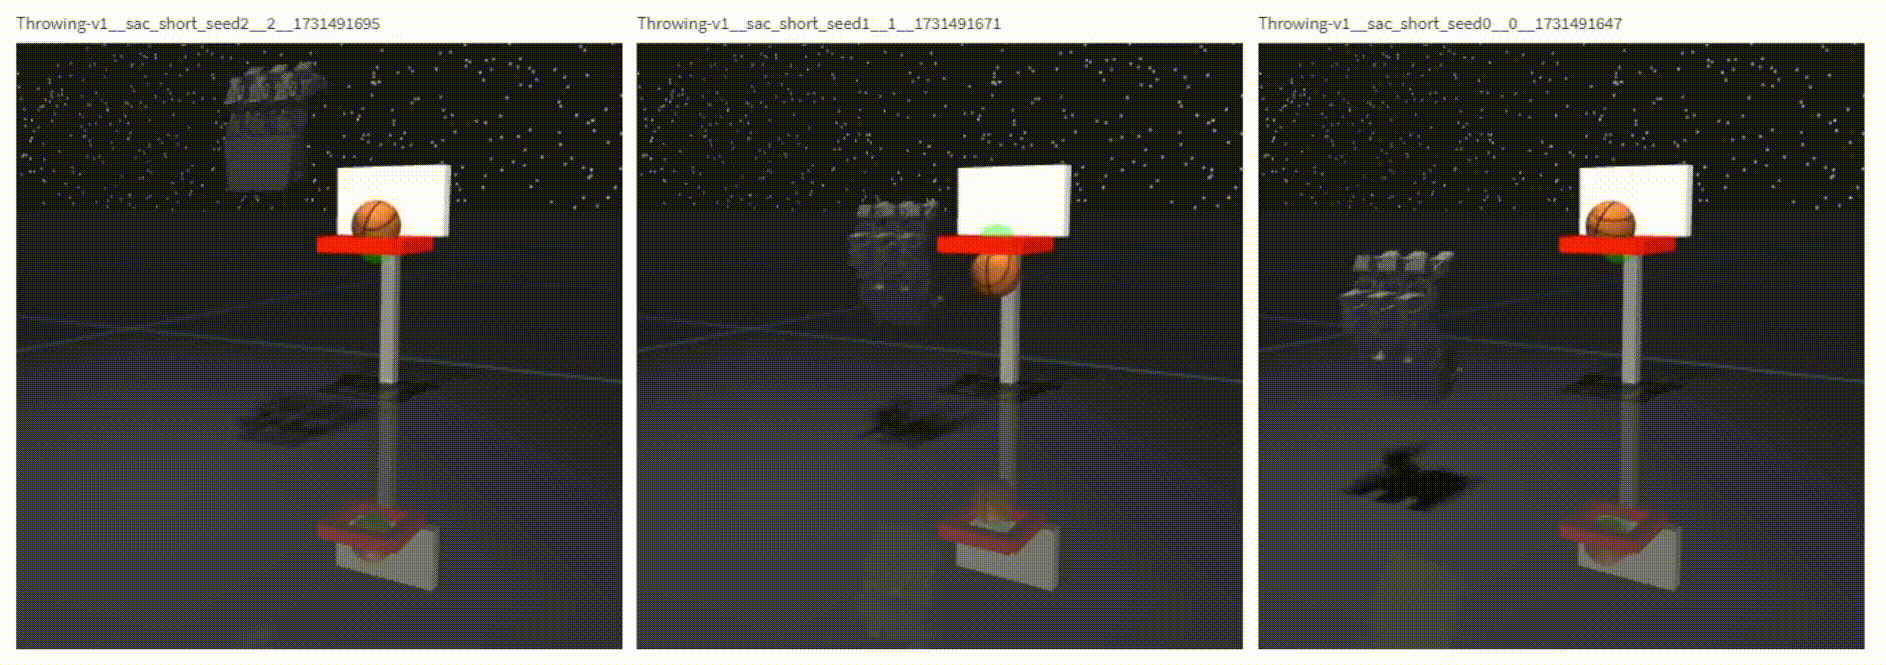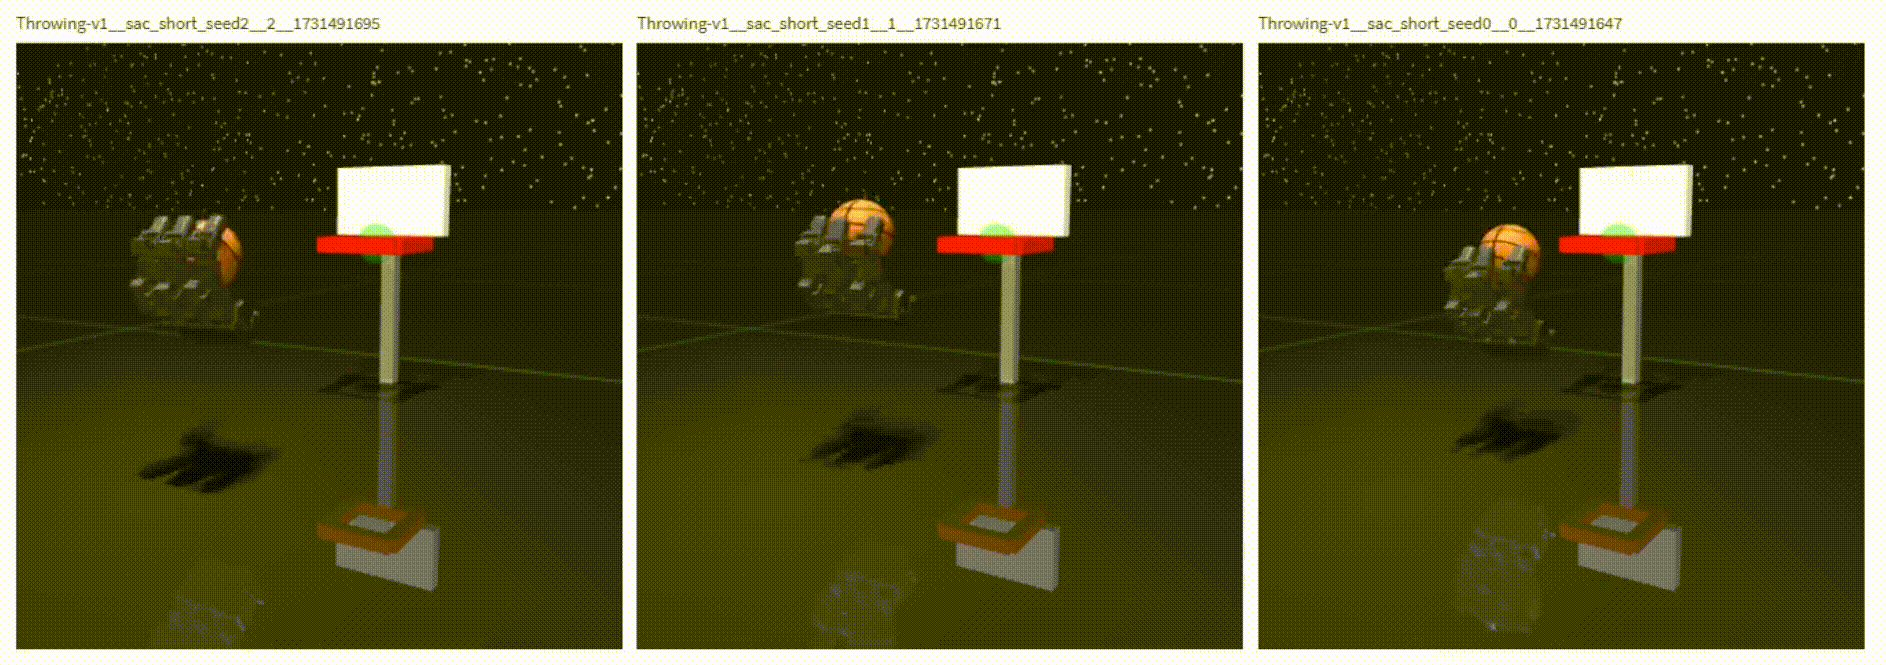 Throw Short
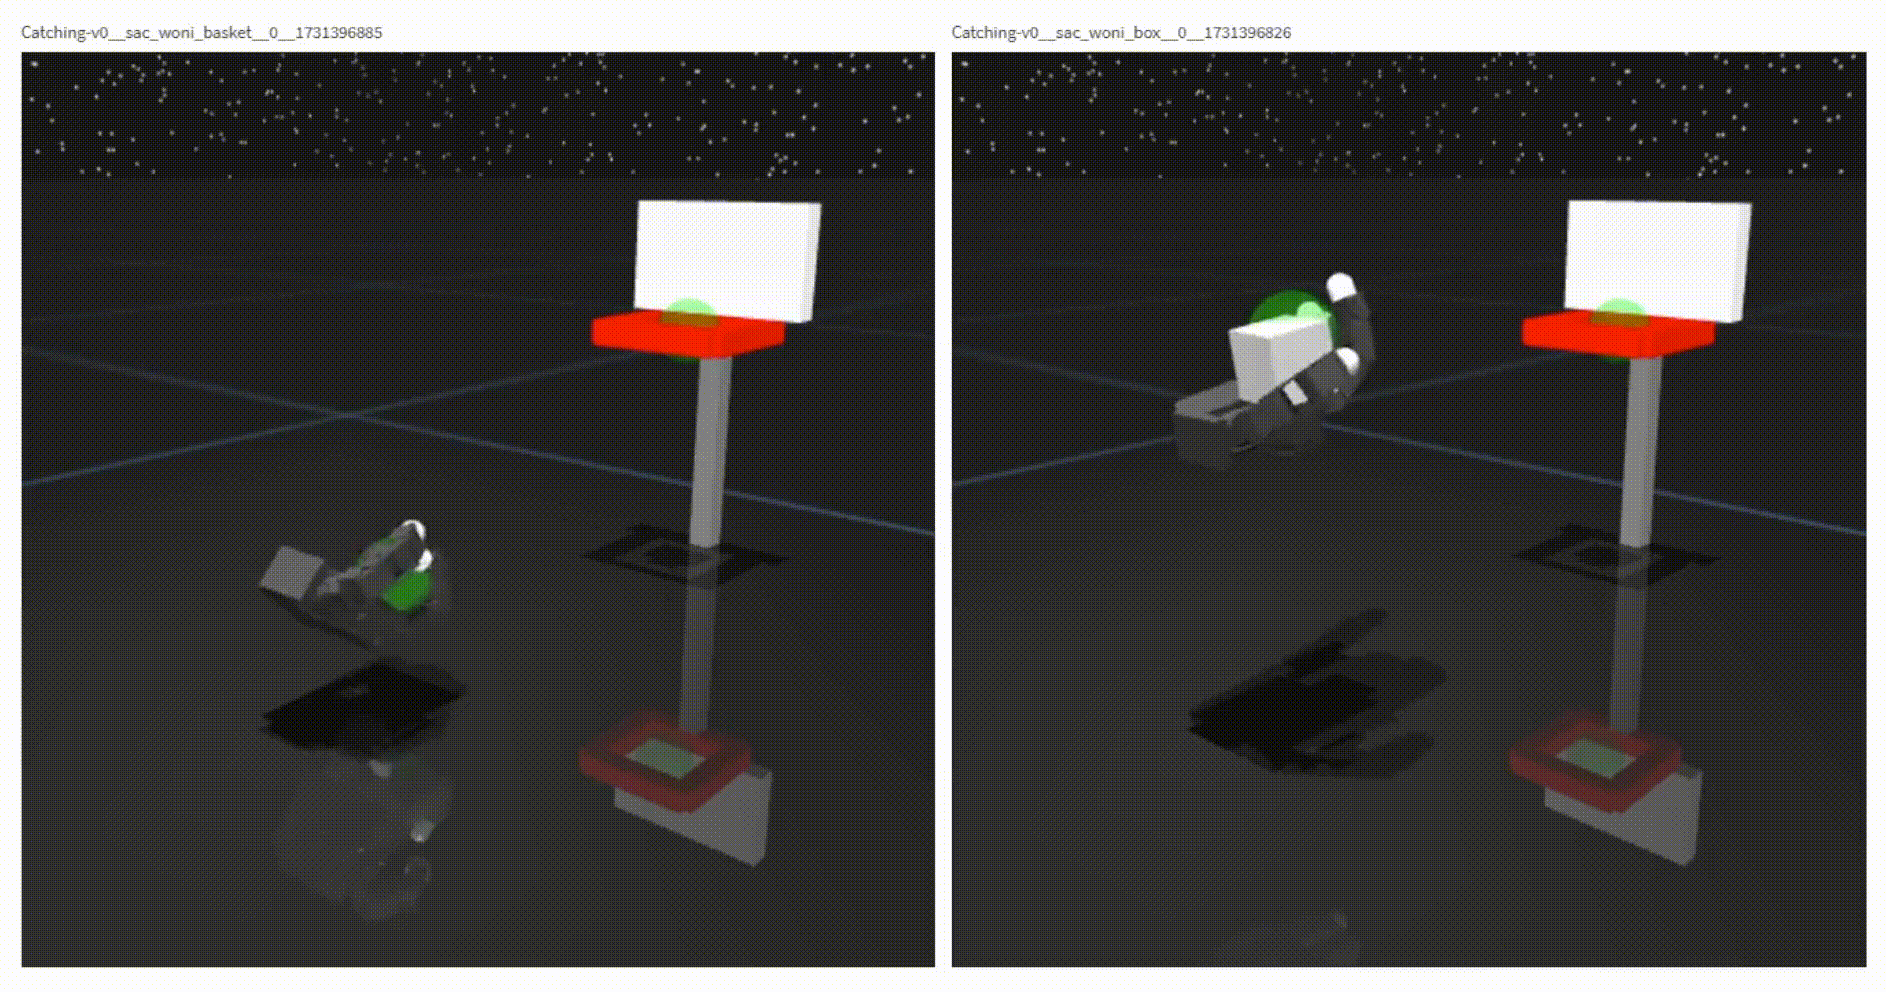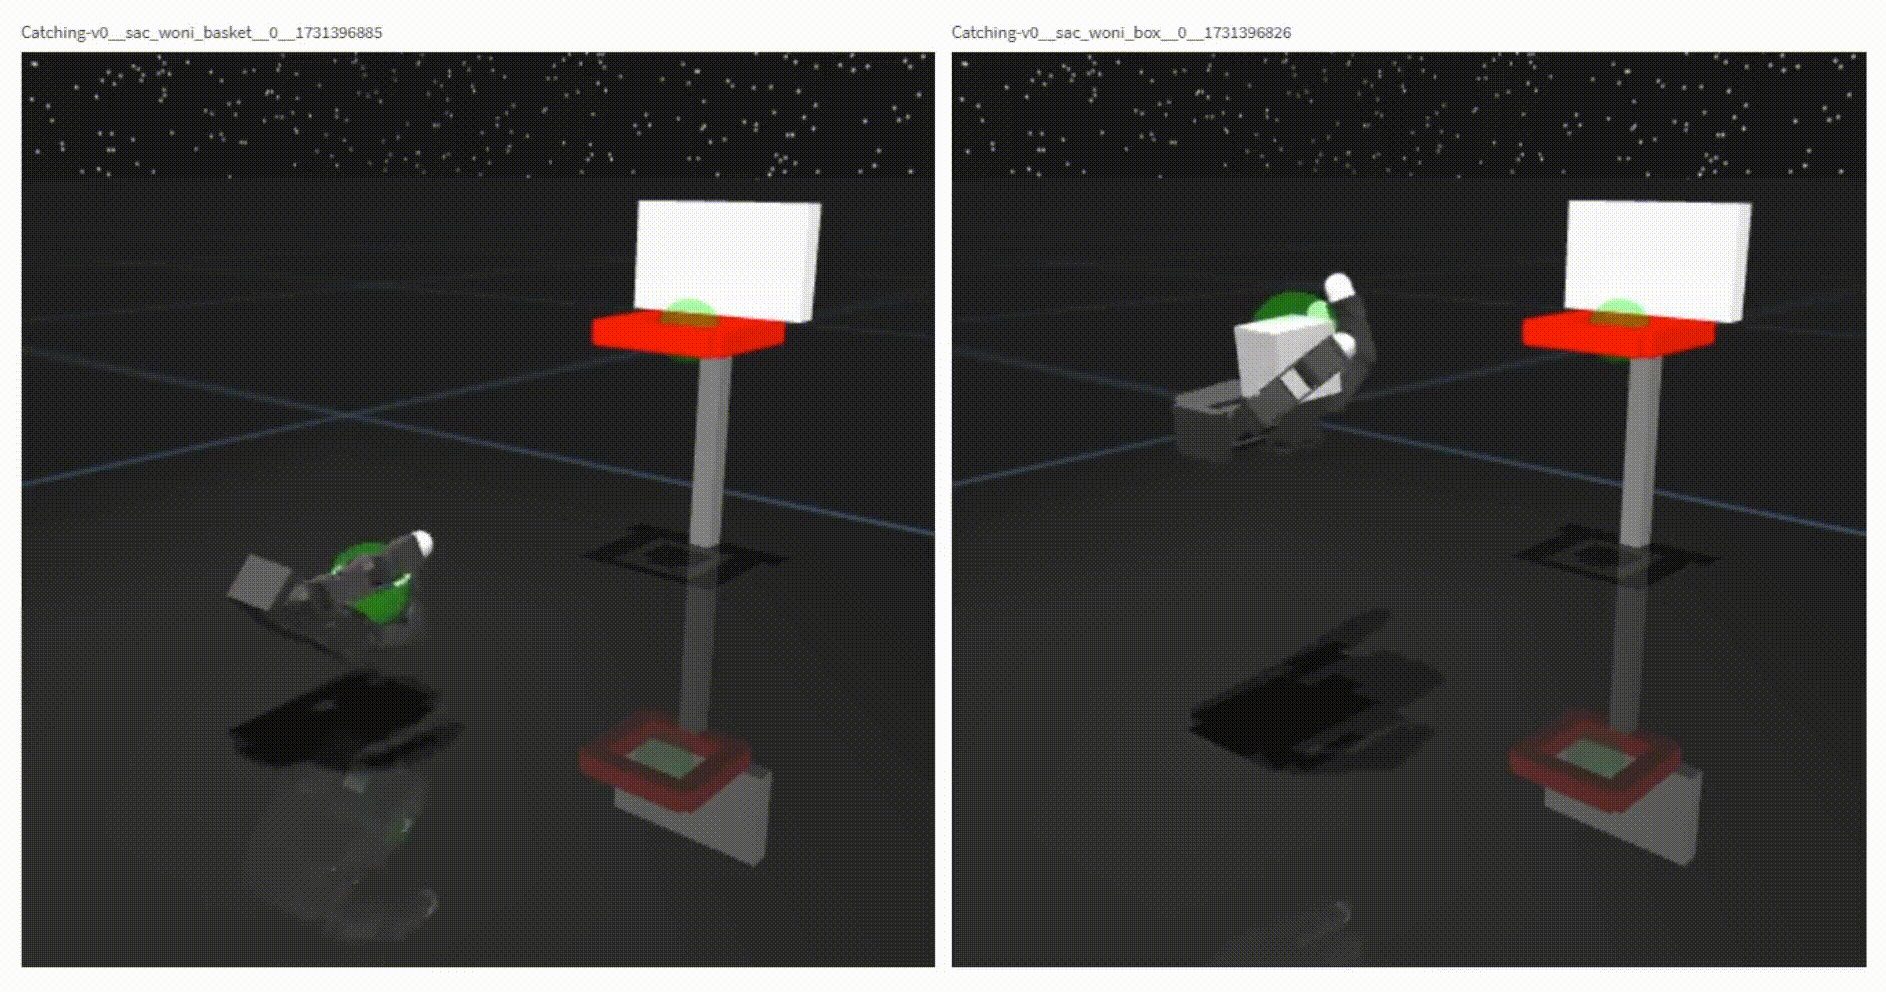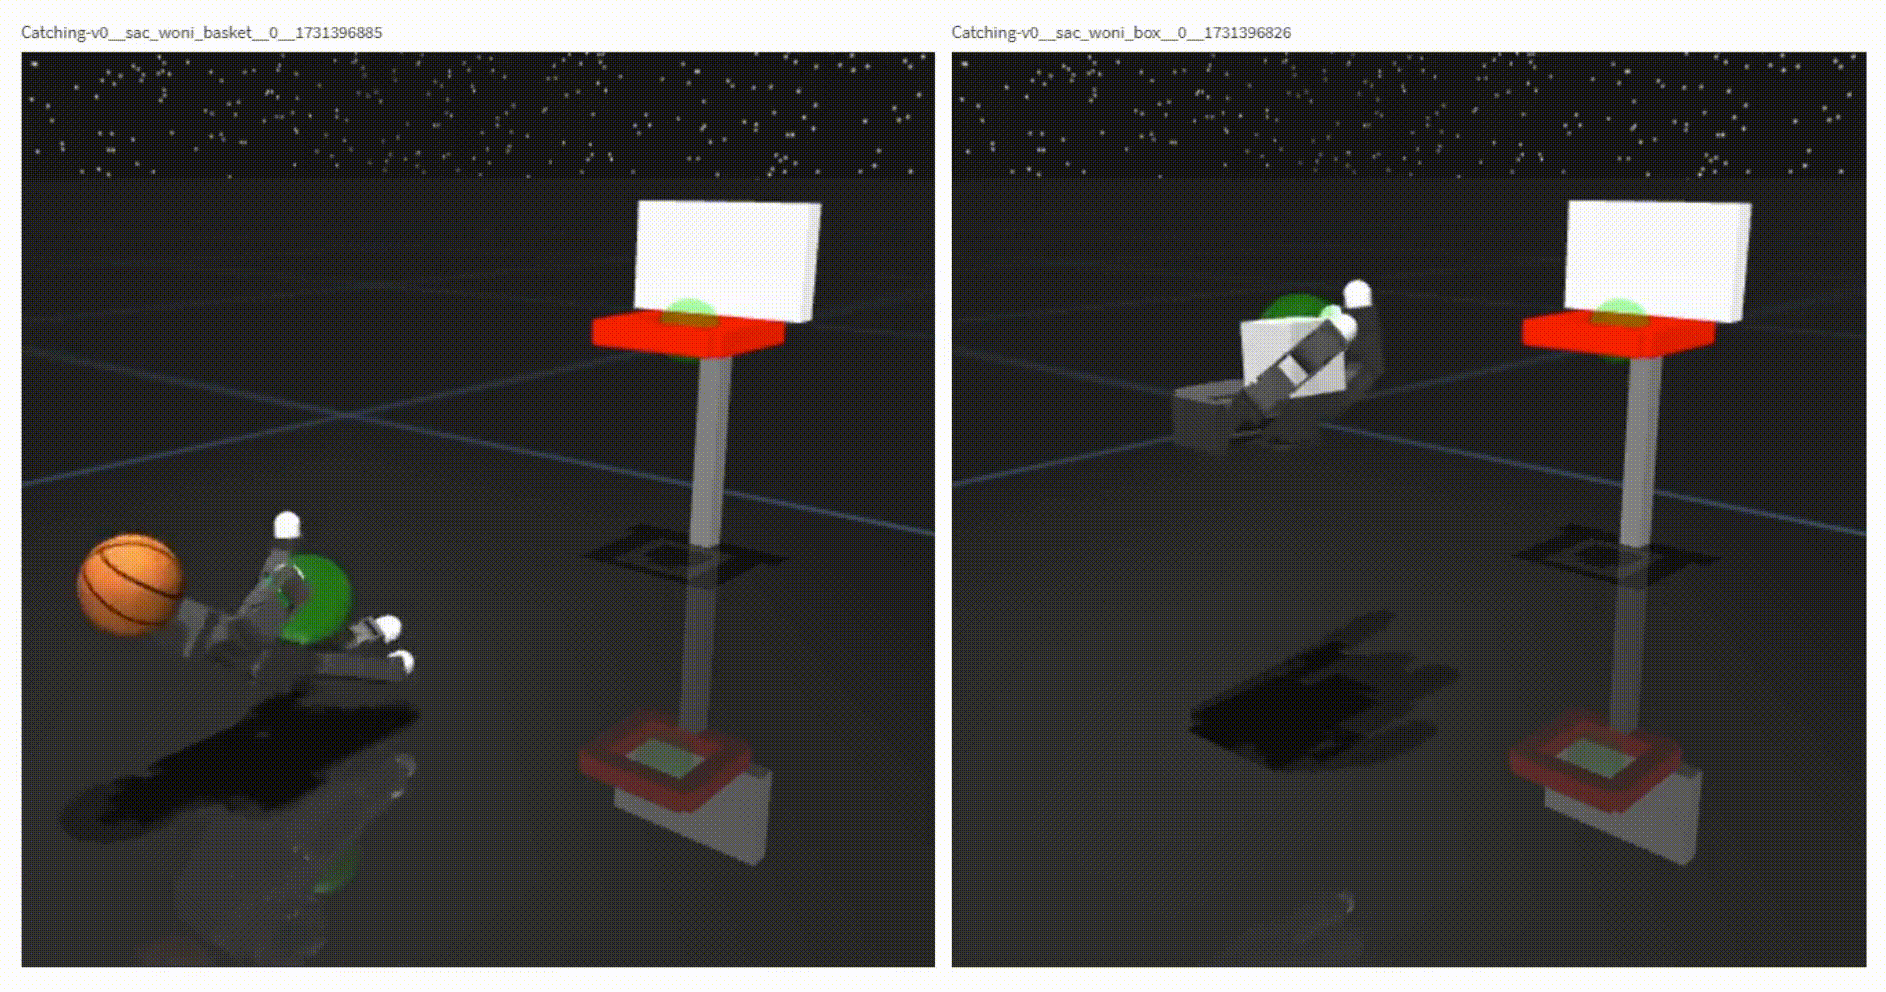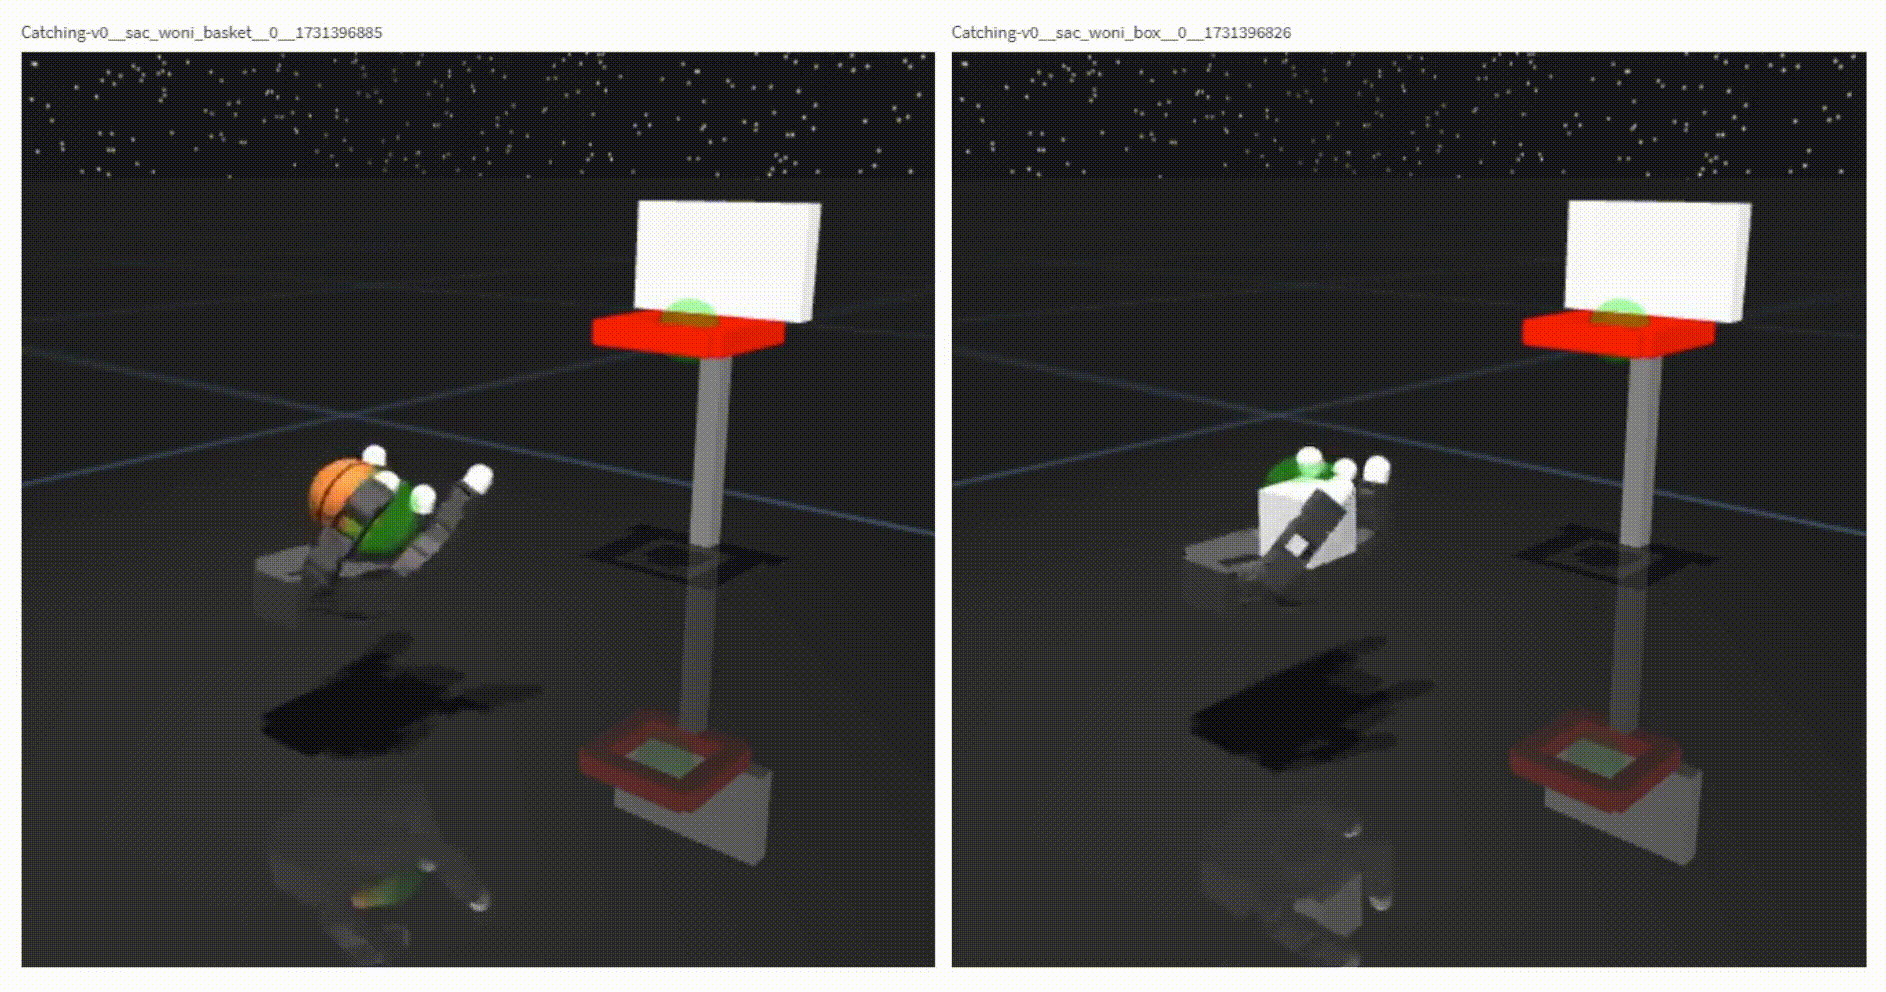 Catch Allegro
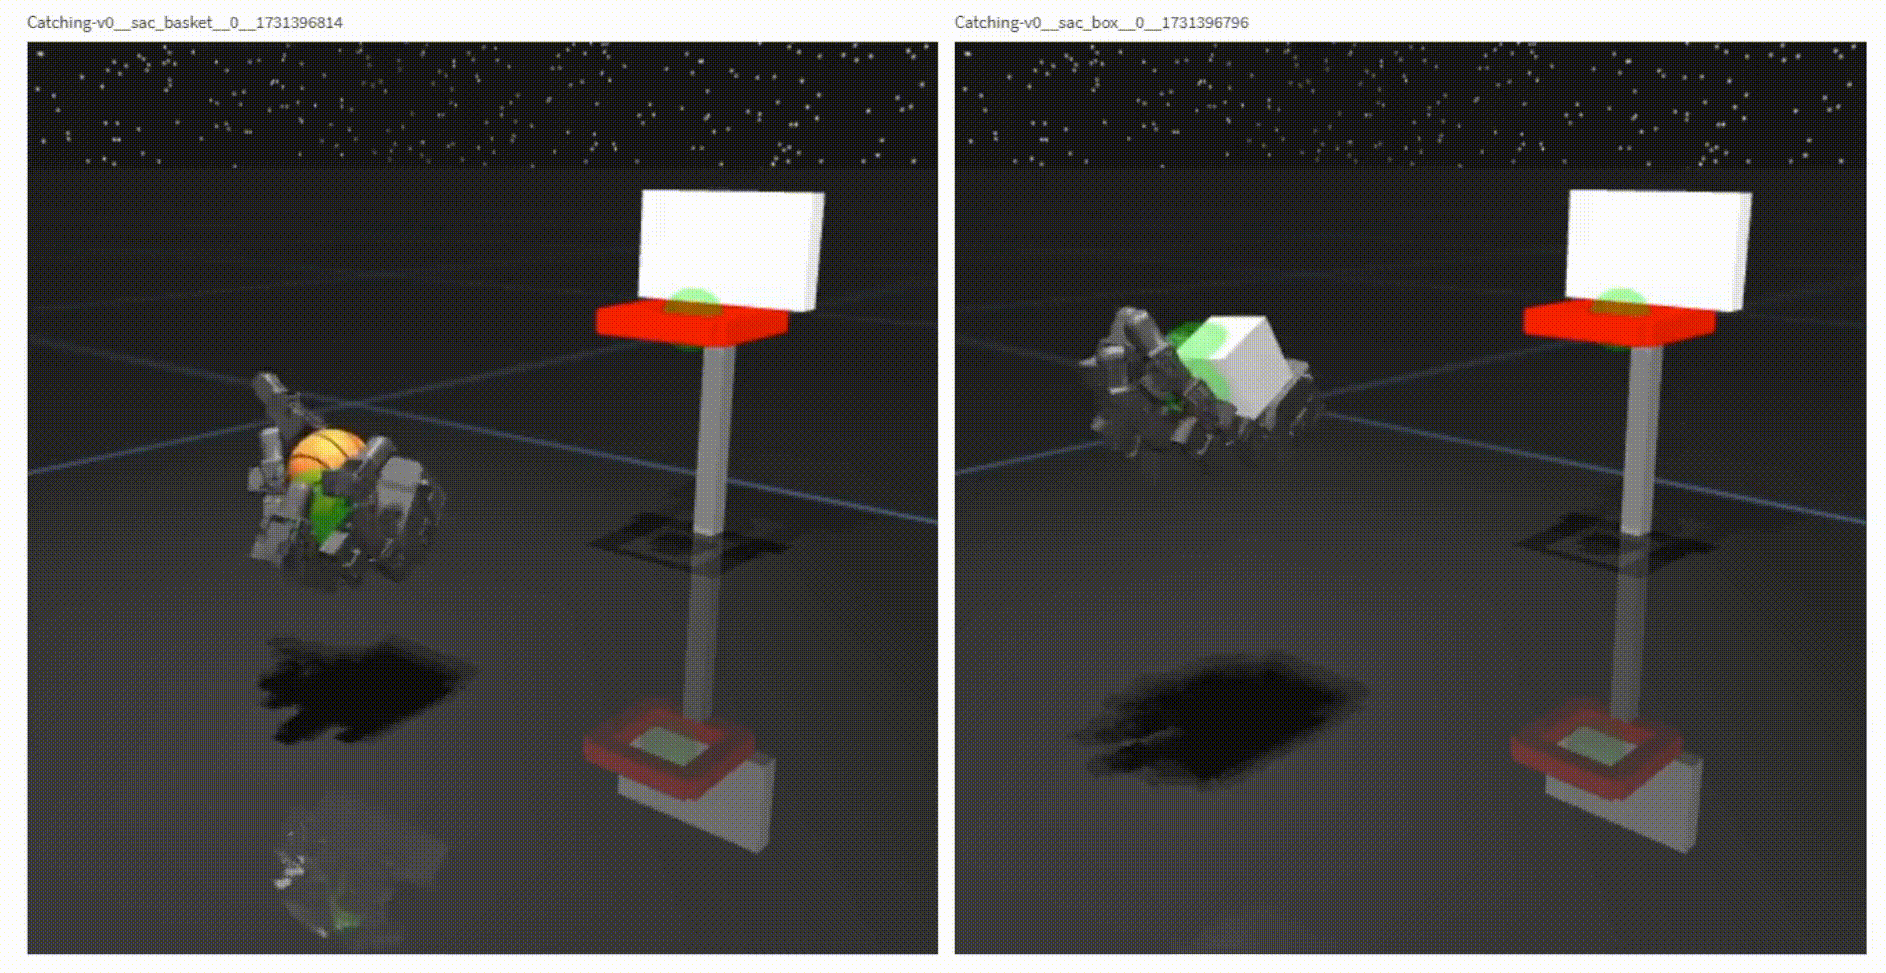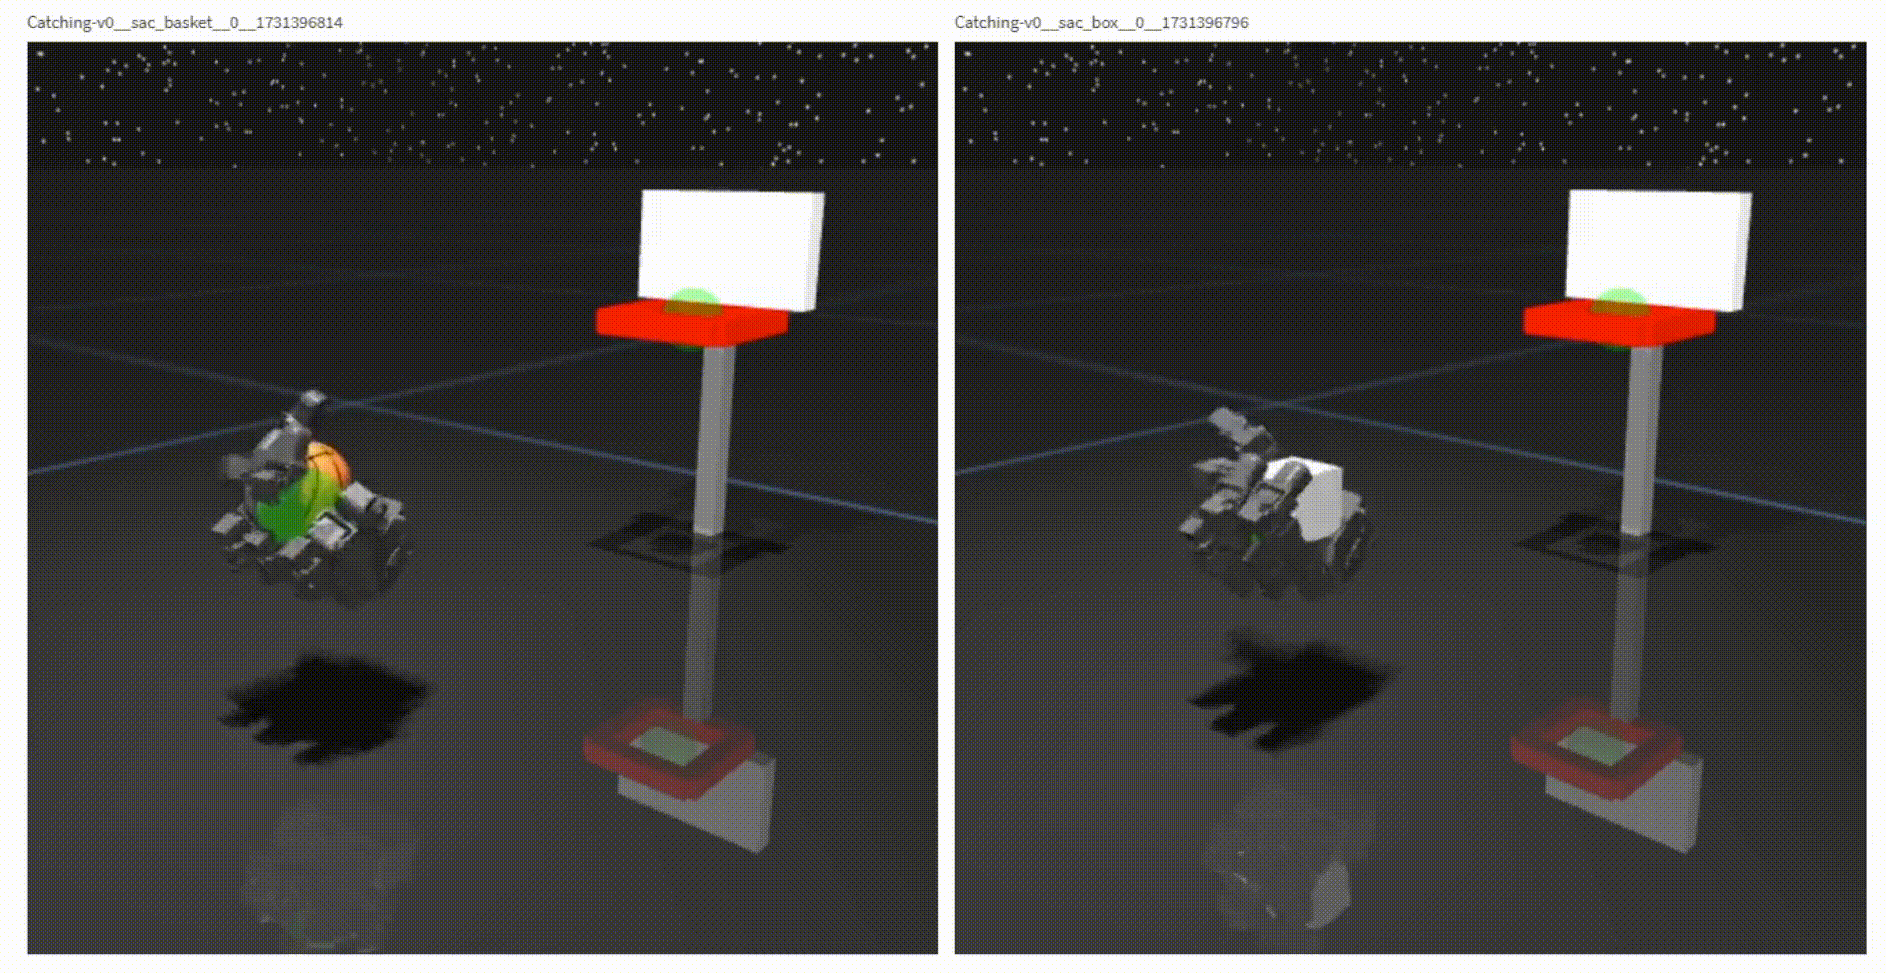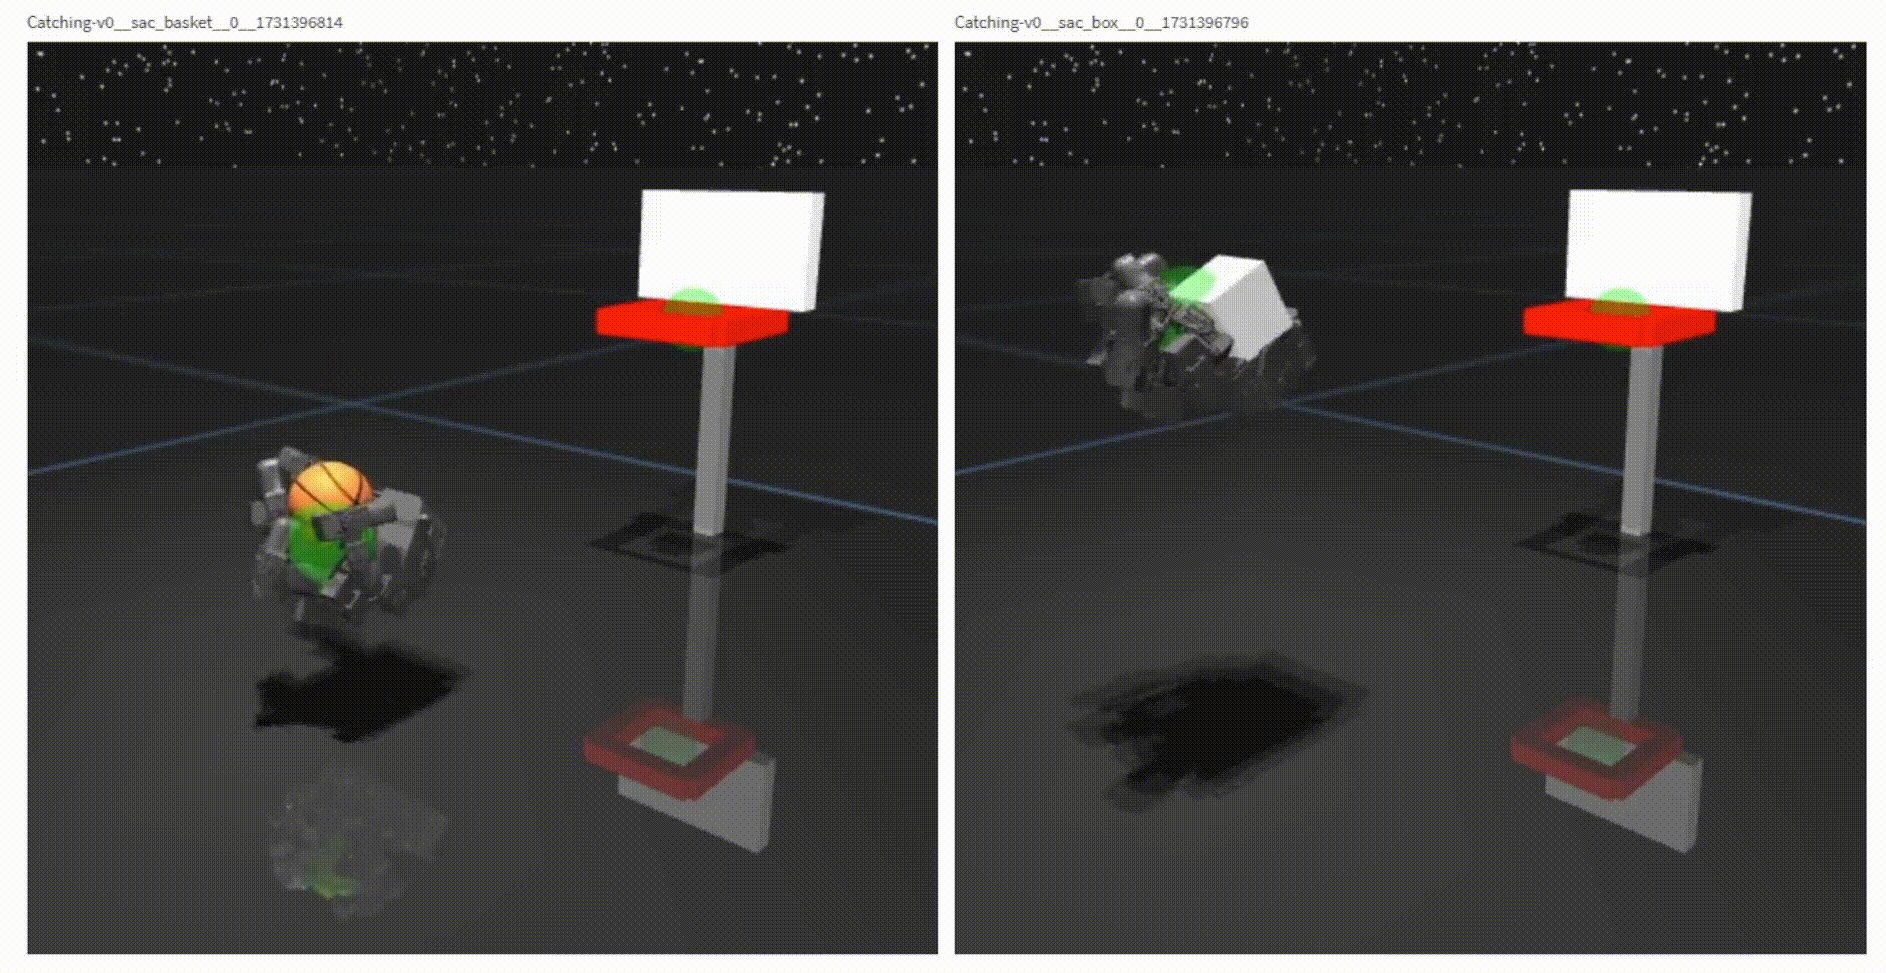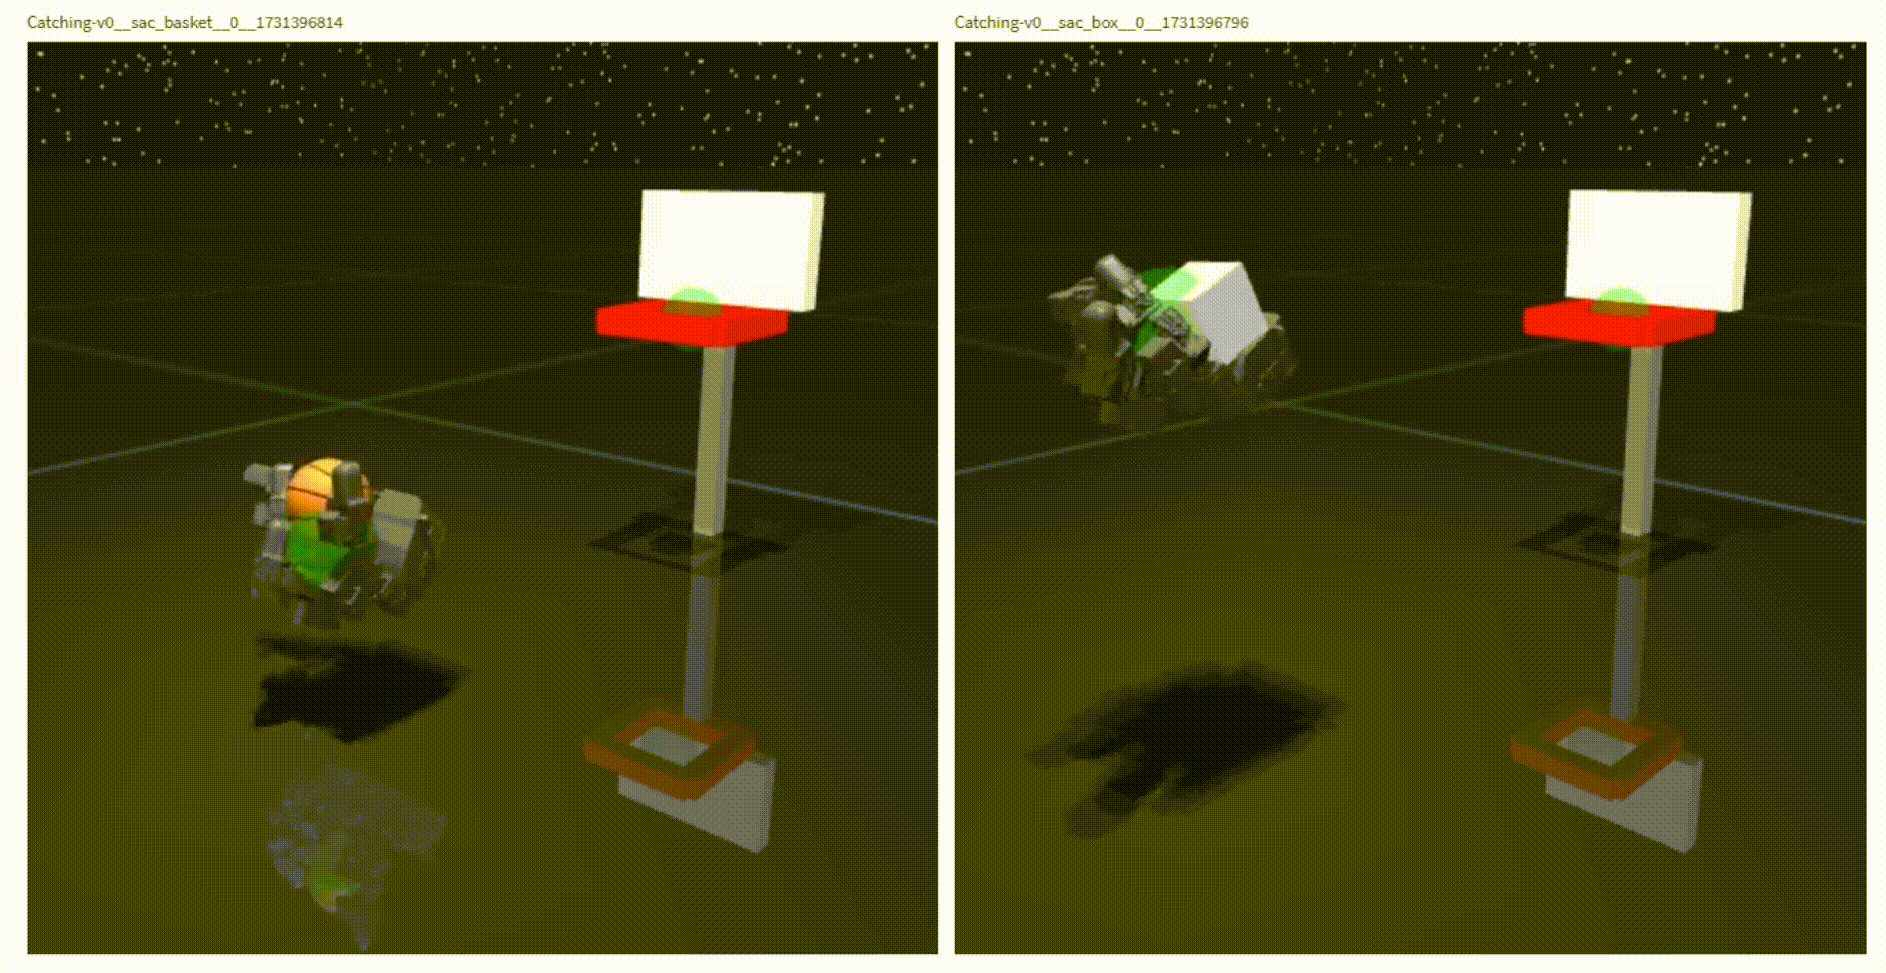 Catch Leap
Technologies:
- Leap Hand & Wonik Allegro models
- Soft Actor-Critic (SAC) algorithm
- GPU-accelerated training
MRI Data Pipeline & GAN-based Augmentation
Engineered MRI data pipeline for 10,000+ scans with GAN-based augmentation for anomaly detection.
Results:
- Improved MRI image quality (1.5T → 3T equivalent)
- 10% improvement in classification accuracy
- Low-latency processing pipeline
Vision-Based Preventive Tool Wear Detection & Data Collection
Developed a computer vision system for continuous data collection and preventive monitoring of tool wear and tear in a manufacturing environment.
Features:
- Automated data collection for tool wear and tear
- Preventive maintenance to reduce unplanned downtime
- Integrated with OPC UA framework for continuous monitoring